2021The brief
Sketching the new system
The team split the work into the electronics, the interface, the filter switcher, the rail and an enclosure, and started from the existing wiring.
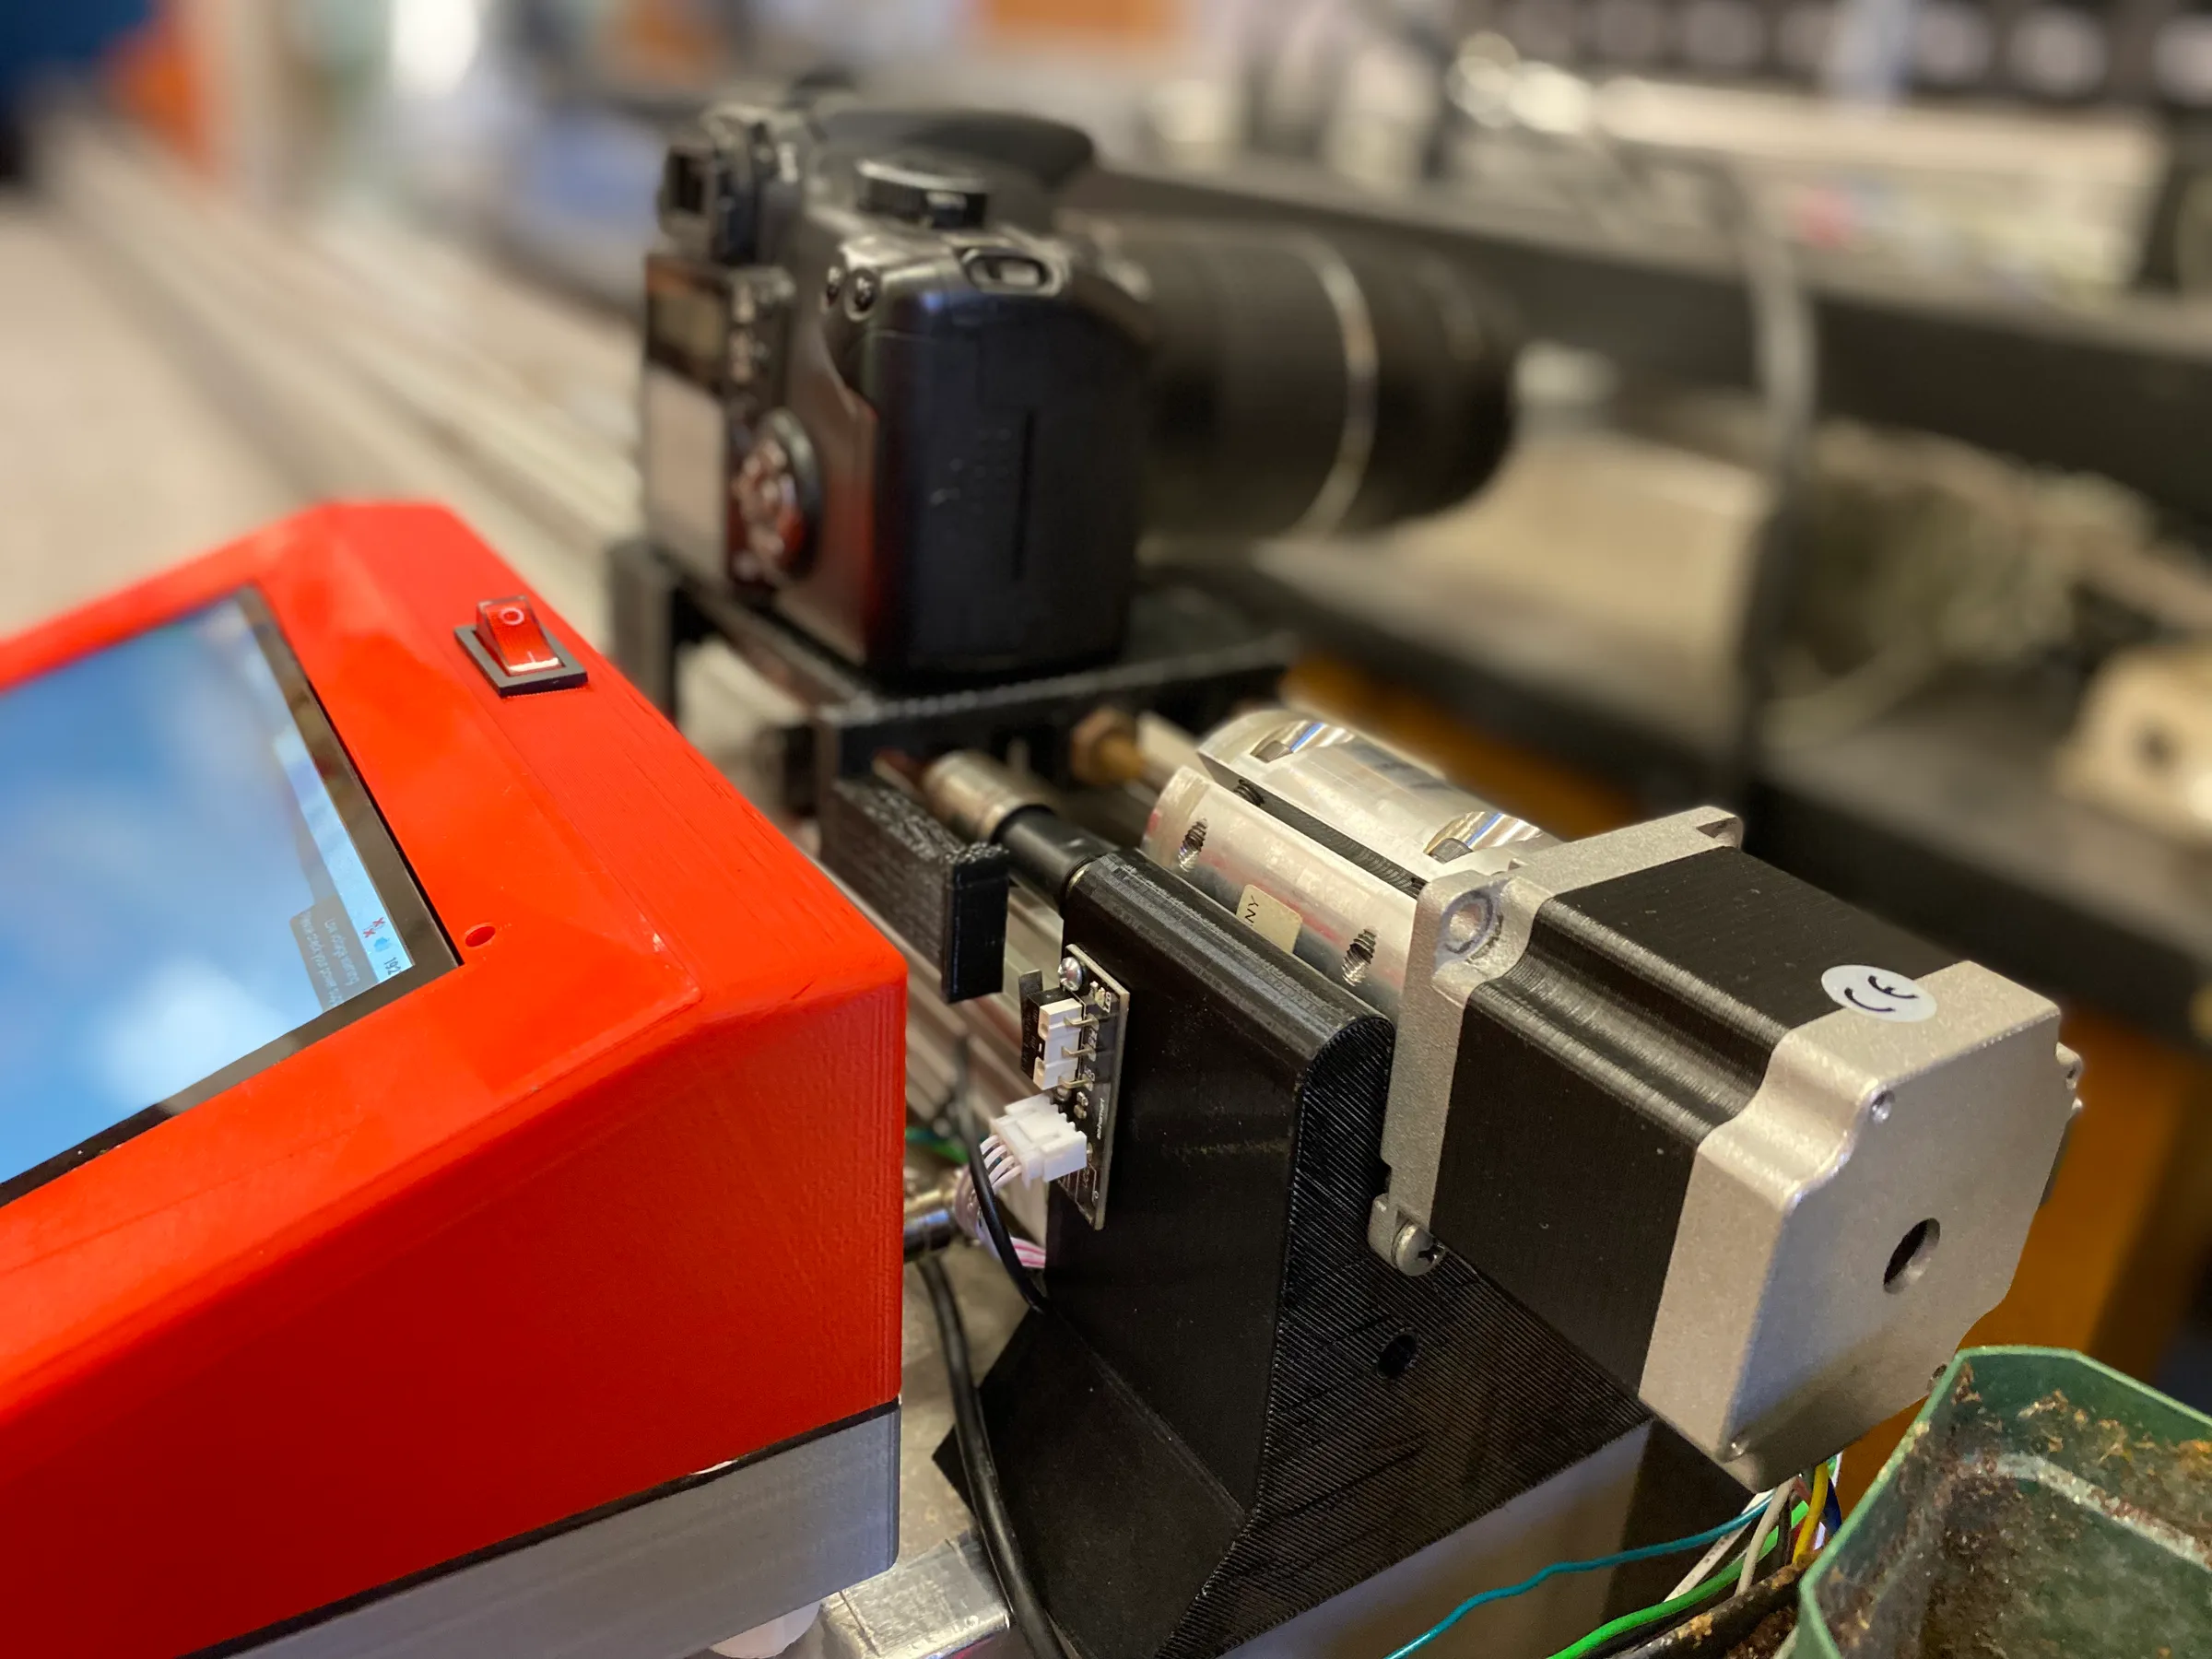
A camera on a linear rail that photographs plant experiments for astrobotany research. The team rebuilt it with a new interface, a touchscreen enclosure, an automatic filter switcher and a sturdier rail.
The problem
In 2014 the Gilroy Lab built a system for a NASA project: arrays of petri dishes photographed by a camera on a 2D pivot.
In 2021 Dr. Richard Barker brought it to Insight Wisconsin. He wanted software that was intuitive to use, a more robust linear rail, an automatic lens switcher and upgrades to the control system.
How it was built
2021The brief
The team split the work into the electronics, the interface, the filter switcher, the rail and an enclosure, and started from the existing wiring.
April 7, 2022Design review
At the design review the team presented every part of the rebuild.
Credits
Dr. Richard Barker, Gilroy Lab, UW–Madison